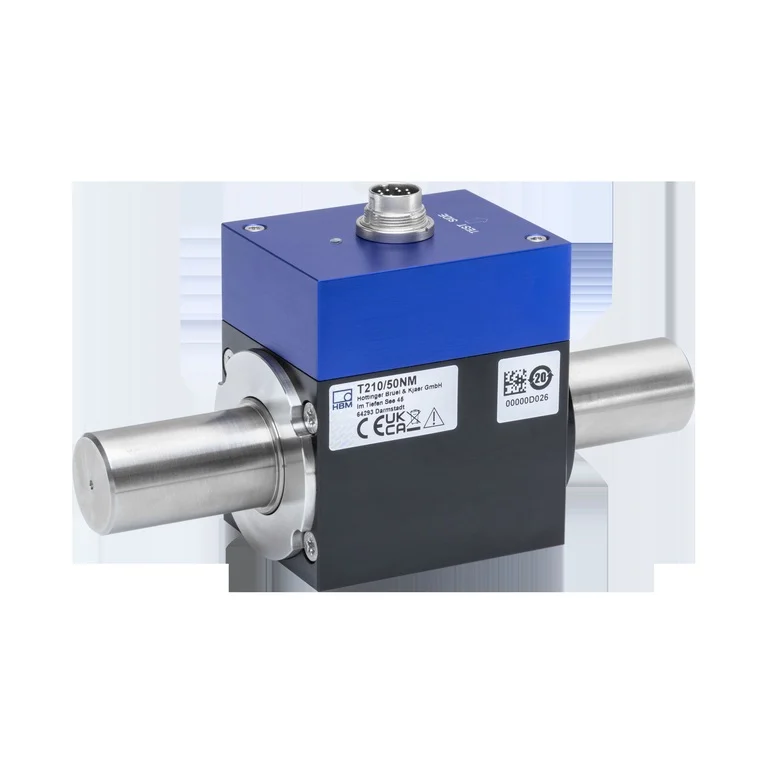
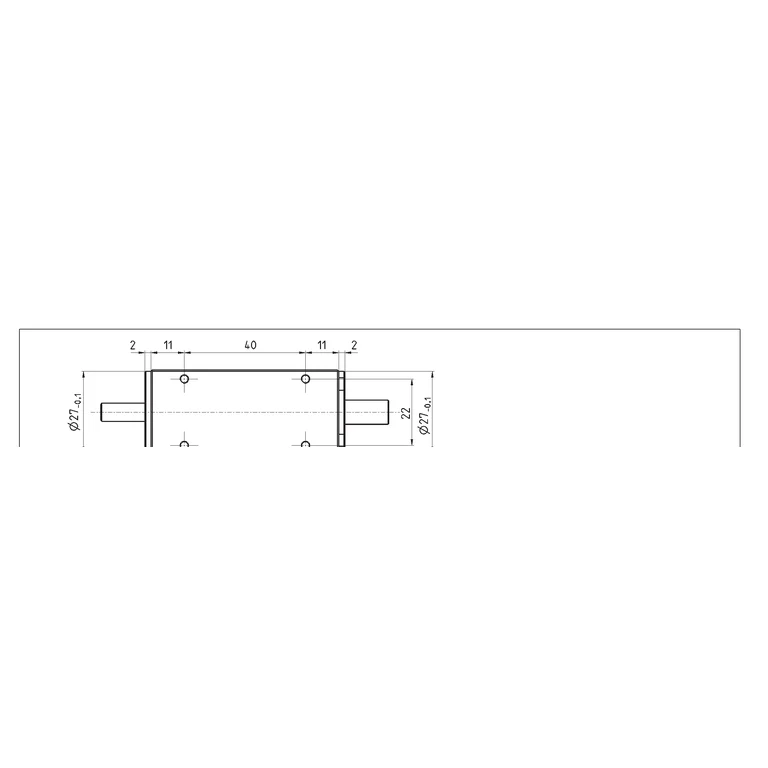
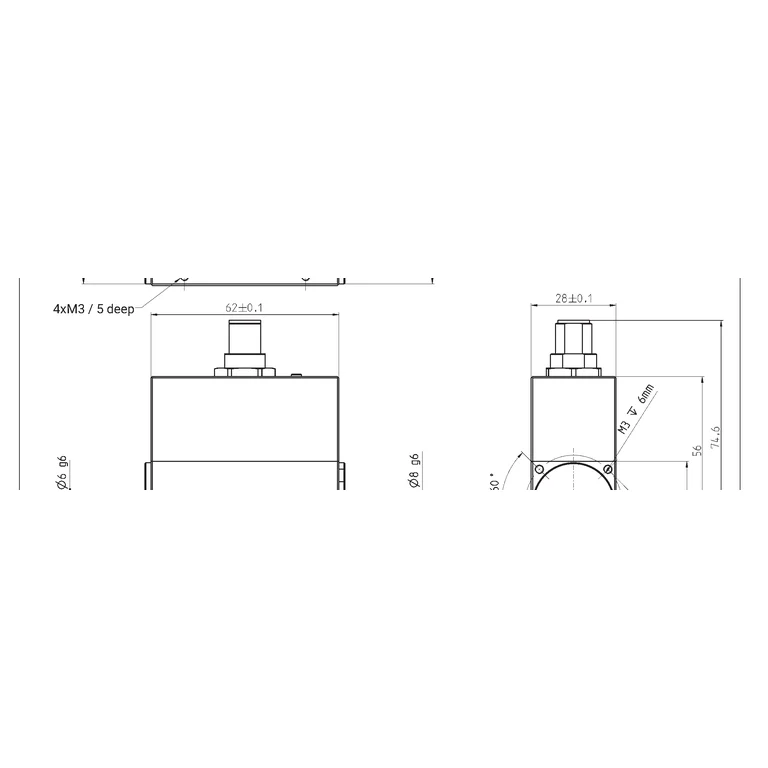
מפרט טכני משותף לסדרה
תכונות שיש לכל דגם בסדרה. מה שמשתנה בין הדגמים מופיע בטבלת הדגמים שלמטה.
| אפשרויות הזמנה ותלויות | K-T210 — capacity: 0.5 N·m, 1 N·m, 2 N·m, 5 N·m, 10 N·m, 20 N·m, 50 N·m, 100 N·m, 200 N·m; size_length: 95 mm (0.5–2 N·m), 145 mm (5–20 N·m), 170 mm (50–200 N·m); accuracy: S; maximum_speed: S; electrical_output: FA (frequency + analog), L (IO-Link); rotational_speed_system: 0 (none), 1 (512 pulses), 2 (1024 pulses), 3 (IO-Link + speed system); custom_modification: N; io_link_firmware: N / IO01 v1.0.0; constraints: [{"when": {"electrical_output": "L (IO-Link)"}, "allow": {"rotational_speed_system": ["0 (none)", "3 (IO-Link + speed system)"]}, "reason": "The T210 ordering data reserves the IO-Link speed-system option for the IO-Link electrical output."}] |
|---|
טווח על פני הדגמים
הטווח שמכסים דגמי הסדרה יחד – לא הטווח של כל דגם.
| ממשקים מובנים | io_link |
|---|---|
| טווח מומנט | -1–1 Nm |
| מהירות סיבוב מרבית | 20000 rpm |
הדגמים בסדרה
עמודה לכל דגם: מה שונה בין דגמי הסדרה.
| פרמטר | 1-T210/0.5NM eli-m-18bc7b94f849f8086833e938 | 1-T210/100NM eli-m-246f018327901d69dd2b452f | 1-T210/10NM eli-m-c8d7c5a12c5a2331e38e01b5 | 1-T210/1NM eli-m-e5459d030de186ff2df409de | 1-T210/200NM eli-m-d2ca42800cada1b0377151a8 | 1-T210/20NM eli-m-901735085a197b1c2f66492b | 1-T210/2NM eli-m-07c3721446ce7ece1c616897 | 1-T210/50NM eli-m-336d58be9fe8b501b4f79f0c | 1-T210/5NM eli-m-4ff45c9f004cfb91dc9490b7 | K-T210 · 0.5 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) eli-m-78818fe65c6dcbfc08e9856a | K-T210 · 0.5 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) eli-m-a44f12cd1e17e2cded19847e | K-T210 · 0.5 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) eli-m-77794b10ade5db836994d055 | K-T210 · 0.5 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) eli-m-be9f850e563a150c5e658ae5 | K-T210 · 0.5 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) eli-m-3cc848888bddcef920e25346 | K-T210 · 1 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) eli-m-fec7e0dabb18d26958d805f3 | K-T210 · 1 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) eli-m-1b102c299edc19c56fb79ead | K-T210 · 1 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) eli-m-333ba019e673c30608e8bd62 | K-T210 · 1 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) eli-m-388b208f60d18b4e7117a497 | K-T210 · 1 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) eli-m-ca8b9adf3f376b766cd7e446 | K-T210 · 10 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) eli-m-4169b051676fe5e0ecb09197 | K-T210 · 10 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) eli-m-fd2166b058aaa29c7ce4ac09 | K-T210 · 10 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) eli-m-4b68aaf67ffab0fe07e3a1c7 | K-T210 · 10 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) eli-m-db2572e5c5ef9663345aaa9f | K-T210 · 10 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) eli-m-4a667fcb189340a650789a68 | K-T210 · 100 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) eli-m-748122817a8fb0077426bfdd | K-T210 · 100 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) eli-m-4669b77badd6dc60c4dd076e | K-T210 · 100 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) eli-m-3978b41c0f8f32311da7700c | K-T210 · 100 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) eli-m-b5453c8a42abc5ca5d14d095 | K-T210 · 100 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) eli-m-d4df958d7810af74d94c07fa | K-T210 · 2 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) eli-m-30d9a02043c18ed9c086bdfd | K-T210 · 2 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) eli-m-2b39e52ef3dd8beb4d73e0a0 | K-T210 · 2 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) eli-m-699356667675373b99869523 | K-T210 · 2 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) eli-m-2b131091cfd74449f85bf8f3 | K-T210 · 2 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) eli-m-5d60ee98072e4934e35fc6b6 | K-T210 · 20 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) eli-m-a127bcf6a4836b589796a9a5 | K-T210 · 20 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) eli-m-088ece57aa0cf42eae3eb113 | K-T210 · 20 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) eli-m-8d4714d31375760d6c3e3c8a | K-T210 · 20 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) eli-m-d15e573ff4e61a421e0f37e6 | K-T210 · 20 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) eli-m-9589e5d0407e25a4b2918c30 | K-T210 · 200 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) eli-m-c9a51c331530dd03ee8435db | K-T210 · 200 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) eli-m-3462c7ed0e484efc8ae9a13e | K-T210 · 200 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) eli-m-f5d6cdb5098e6ef6d0cbd71c | K-T210 · 200 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) eli-m-b24804a465b7a8e627767b55 | K-T210 · 200 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) eli-m-bc313c861f9b331e22df6b94 | K-T210 · 5 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) eli-m-7898570db93bb72b710d5ebf | K-T210 · 5 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) eli-m-cfe74b42dd5627dc21d8f6e7 | K-T210 · 5 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) eli-m-a4c11c65b657c53d4618a8d1 | K-T210 · 5 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) eli-m-e277e78e78915cc93c2b7623 | K-T210 · 5 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) eli-m-b87bbe1c45f0820d96757a8b | K-T210 · 50 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) eli-m-6933c707ca3a2a082ccf4e79 | K-T210 · 50 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) eli-m-621ce18e9ce49a1694e09bf9 | K-T210 · 50 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) eli-m-691037a83a6fa2528f9c9cf2 | K-T210 · 50 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) eli-m-6d1ae348bf837cce950e3ec2 | K-T210 · 50 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) eli-m-a5681c510aaf81683a355200 | T210-100Nm eli-m-b9476038f527423b49d31cfd | T210-10Nm eli-m-0356cd491f5920bc33a2318a | T210-1Nm eli-m-c25d09310aab09e4436559e3 | T210-200Nm eli-m-0b115278741bc0e796f9c147 | T210-20Nm eli-m-0bbcaa49dcb7e964d2591481 | T210-2Nm eli-m-9d98e40f8ca76ac2f7e432af | T210-500Nmm eli-m-9ffa6f471a81fe2867e40cac | T210-50Nm eli-m-19e615c10874a65781e4904e | T210-5Nm eli-m-c749e37734a628d3f2c55c0e |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| ממשקים מובנים | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | io_link | io_link | לא צוין | לא צוין | לא צוין | io_link | io_link | לא צוין | לא צוין | לא צוין | io_link | io_link | לא צוין | לא צוין | לא צוין | io_link | io_link | לא צוין | לא צוין | לא צוין | io_link | io_link | לא צוין | לא צוין | לא צוין | io_link | io_link | לא צוין | לא צוין | לא צוין | io_link | io_link | לא צוין | לא צוין | לא צוין | io_link | io_link | לא צוין | לא צוין | לא צוין | io_link | io_link | ethernet | ethercat | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet |
| טווח מומנט | -0.5–0.5 Nm | -100–100 Nm | -10–10 Nm | -1–1 Nm | -200–200 Nm | -20–20 Nm | -2–2 Nm | -50–50 Nm | -5–5 Nm | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | -100–100 Nm | -10–10 Nm | -1–1 Nm | -200–200 Nm | -20–20 Nm | -2–2 Nm | -0.5–0.5 Nm | -50–50 Nm | -5–5 Nm |
| מהירות סיבוב מרבית | 30000 rpm | 14000 rpm | 20000 rpm | 30000 rpm | 14000 rpm | 20000 rpm | 30000 rpm | 14000 rpm | 20000 rpm | 30000 rpm | 30000 rpm | 30000 rpm | 30000 rpm | 30000 rpm | 30000 rpm | 30000 rpm | 30000 rpm | 30000 rpm | 30000 rpm | 20000 rpm | 20000 rpm | 20000 rpm | 20000 rpm | 20000 rpm | 14000 rpm | 14000 rpm | 14000 rpm | 14000 rpm | 14000 rpm | 30000 rpm | 30000 rpm | 30000 rpm | 30000 rpm | 30000 rpm | 20000 rpm | 20000 rpm | 20000 rpm | 20000 rpm | 20000 rpm | 14000 rpm | 14000 rpm | 14000 rpm | 14000 rpm | 14000 rpm | 20000 rpm | 20000 rpm | 20000 rpm | 20000 rpm | 20000 rpm | 14000 rpm | 14000 rpm | 14000 rpm | 14000 rpm | 14000 rpm | 14000 rpm | 20000 rpm | 30000 rpm | 14000 rpm | 20000 rpm | 30000 rpm | 30000 rpm | 14000 rpm | 20000 rpm |
| פרטי ממשק ואות לפי המקור | Analog 0-10V | Digital I/O | Digital I/O | Analog 0-10V | Digital I/O | Analog 0-10V | Analog 0-10V | Analog 0-10V | Analog 0-10V | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין |
| נתון טכני לפי גודל ובסיס במקור | Actions: Not sellable online; Measurement range: 4.43 in-lb; Nominal rotational speed: 30000 rpm; Size (length): 3.74 in; Output signal: Voltage (+/- 10V), Frequency | Actions: Not sellable online; Measurement range: 885 in-lb; Nominal rotational speed: 14000 rpm; Size (length): 6.69 in; Output signal: Voltage (+/- 10V), Frequency | Actions: Not sellable online; Measurement range: 88.5 in-lb; Nominal rotational speed: 20000 rpm; Size (length): 5.71 in; Output signal: Voltage (+/- 10V), Frequency | Actions: Not sellable online; Measurement range: 8.85 in-lb; Nominal rotational speed: 30000 rpm; Size (length): 3.74 in; Output signal: Voltage (+/- 10V), Frequency | Actions: Not sellable online; Measurement range: 1770 in-lb; Nominal rotational speed: 14000 rpm; Size (length): 6.69 in; Output signal: Voltage (+/- 10V), Frequency | Actions: Not sellable online; Measurement range: 177 in-lb; Nominal rotational speed: 20000 rpm; Size (length): 5.71 in; Output signal: Voltage (+/- 10V), Frequency | Actions: Not sellable online; Measurement range: 17.7 in-lb; Nominal rotational speed: 30000 rpm; Size (length): 3.74 in; Output signal: Voltage (+/- 10V), Frequency | Actions: Not sellable online; Measurement range: 443 in-lb; Nominal rotational speed: 14000 rpm; Size (length): 6.69 in; Output signal: Voltage (+/- 10V), Frequency | Actions: Not sellable online; Measurement range: 44.3 in-lb; Nominal rotational speed: 20000 rpm; Size (length): 5.71 in; Output signal: Voltage (+/- 10V), Frequency | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | ±100 Nm rated torque; rotating installation; maximum 14,000 rpm | ±10 Nm rated torque; rotating installation; maximum 20,000 rpm | ±1 Nm rated torque; rotating installation; maximum 30,000 rpm | ±200 Nm rated torque; rotating installation; maximum 14,000 rpm | ±20 Nm rated torque; rotating installation; maximum 20,000 rpm | ±2 Nm rated torque; rotating installation; maximum 30,000 rpm | ±500 Nmm rated torque; rotating installation; maximum 30,000 rpm | ±50 Nm rated torque; rotating installation; maximum 14,000 rpm | ±5 Nm rated torque; rotating installation; maximum 20,000 rpm |
| בסיס הגדרת חזרתיות | Use the individual calibration certificate and installed-chain verification; no unsupported scalar repeatability is inferred. | Use the individual calibration certificate and installed-chain verification; no unsupported scalar repeatability is inferred. | Use the individual calibration certificate and installed-chain verification; no unsupported scalar repeatability is inferred. | Use the individual calibration certificate and installed-chain verification; no unsupported scalar repeatability is inferred. | Use the individual calibration certificate and installed-chain verification; no unsupported scalar repeatability is inferred. | Use the individual calibration certificate and installed-chain verification; no unsupported scalar repeatability is inferred. | Use the individual calibration certificate and installed-chain verification; no unsupported scalar repeatability is inferred. | Use the individual calibration certificate and installed-chain verification; no unsupported scalar repeatability is inferred. | Use the individual calibration certificate and installed-chain verification; no unsupported scalar repeatability is inferred. | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין |
| יכולת מדידת מהירות סיבוב | True | True | True | True | True | True | True | True | True | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | True | True | True | True | True | True | True | True | True |
| בסיס הגדרת לינאריות | No single accuracy class is inferred when it is not shown for the exact ordering code. | No single accuracy class is inferred when it is not shown for the exact ordering code. | No single accuracy class is inferred when it is not shown for the exact ordering code. | No single accuracy class is inferred when it is not shown for the exact ordering code. | No single accuracy class is inferred when it is not shown for the exact ordering code. | No single accuracy class is inferred when it is not shown for the exact ordering code. | No single accuracy class is inferred when it is not shown for the exact ordering code. | No single accuracy class is inferred when it is not shown for the exact ordering code. | No single accuracy class is inferred when it is not shown for the exact ordering code. | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין |
| בסיס קצב הדגימה | Torque and speed outputs are conditioned by the selected HBK interface; no unsupported digital rate is inferred. | Torque and speed outputs are conditioned by the selected HBK interface; no unsupported digital rate is inferred. | Torque and speed outputs are conditioned by the selected HBK interface; no unsupported digital rate is inferred. | Torque and speed outputs are conditioned by the selected HBK interface; no unsupported digital rate is inferred. | Torque and speed outputs are conditioned by the selected HBK interface; no unsupported digital rate is inferred. | Torque and speed outputs are conditioned by the selected HBK interface; no unsupported digital rate is inferred. | Torque and speed outputs are conditioned by the selected HBK interface; no unsupported digital rate is inferred. | Torque and speed outputs are conditioned by the selected HBK interface; no unsupported digital rate is inferred. | Torque and speed outputs are conditioned by the selected HBK interface; no unsupported digital rate is inferred. | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | MX840B maximum per-channel sample rate; sensor mechanics and filter settings can reduce usable bandwidth | MX840B maximum per-channel sample rate; sensor mechanics and filter settings can reduce usable bandwidth | MX840B maximum per-channel sample rate; sensor mechanics and filter settings can reduce usable bandwidth | MX840B maximum per-channel sample rate; sensor mechanics and filter settings can reduce usable bandwidth | MX840B maximum per-channel sample rate; sensor mechanics and filter settings can reduce usable bandwidth | MX840B maximum per-channel sample rate; sensor mechanics and filter settings can reduce usable bandwidth | MX840B maximum per-channel sample rate; sensor mechanics and filter settings can reduce usable bandwidth | MX840B maximum per-channel sample rate; sensor mechanics and filter settings can reduce usable bandwidth | MX840B maximum per-channel sample rate; sensor mechanics and filter settings can reduce usable bandwidth |
| יציאת חיישן לחץ | Voltage (+/- 10V), Frequency | Voltage (+/- 10V), Frequency | Voltage (+/- 10V), Frequency | Voltage (+/- 10V), Frequency | Voltage (+/- 10V), Frequency | Voltage (+/- 10V), Frequency | Voltage (+/- 10V), Frequency | Voltage (+/- 10V), Frequency | Voltage (+/- 10V), Frequency | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין |
| מגבלת קצב בגלל קריאת המערכת | False | False | False | False | False | False | False | False | False | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין |
| אפשרויות שנבחרו בתצורה | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | accuracy=S;maximum_speed=S;size_length=95 mm (0.5–2 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=95 mm (0.5–2 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=1 (512 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=95 mm (0.5–2 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=2 (1024 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=95 mm (0.5–2 N·m);electrical_output=L (IO-Link);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=95 mm (0.5–2 N·m);electrical_output=L (IO-Link);rotational_speed_system=3 (IO-Link + speed system);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=95 mm (0.5–2 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=95 mm (0.5–2 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=1 (512 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=95 mm (0.5–2 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=2 (1024 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=95 mm (0.5–2 N·m);electrical_output=L (IO-Link);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=95 mm (0.5–2 N·m);electrical_output=L (IO-Link);rotational_speed_system=3 (IO-Link + speed system);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=145 mm (5–20 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=145 mm (5–20 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=1 (512 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=145 mm (5–20 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=2 (1024 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=145 mm (5–20 N·m);electrical_output=L (IO-Link);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=145 mm (5–20 N·m);electrical_output=L (IO-Link);rotational_speed_system=3 (IO-Link + speed system);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=1 (512 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=2 (1024 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=L (IO-Link);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=L (IO-Link);rotational_speed_system=3 (IO-Link + speed system);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=95 mm (0.5–2 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=95 mm (0.5–2 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=1 (512 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=95 mm (0.5–2 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=2 (1024 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=95 mm (0.5–2 N·m);electrical_output=L (IO-Link);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=95 mm (0.5–2 N·m);electrical_output=L (IO-Link);rotational_speed_system=3 (IO-Link + speed system);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=145 mm (5–20 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=145 mm (5–20 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=1 (512 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=145 mm (5–20 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=2 (1024 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=145 mm (5–20 N·m);electrical_output=L (IO-Link);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=145 mm (5–20 N·m);electrical_output=L (IO-Link);rotational_speed_system=3 (IO-Link + speed system);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=1 (512 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=2 (1024 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=L (IO-Link);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=L (IO-Link);rotational_speed_system=3 (IO-Link + speed system);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=145 mm (5–20 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=145 mm (5–20 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=1 (512 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=145 mm (5–20 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=2 (1024 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=145 mm (5–20 N·m);electrical_output=L (IO-Link);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=145 mm (5–20 N·m);electrical_output=L (IO-Link);rotational_speed_system=3 (IO-Link + speed system);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=1 (512 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=2 (1024 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=L (IO-Link);rotational_speed_system=0 (none);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=L (IO-Link);rotational_speed_system=3 (IO-Link + speed system);custom_modification=N;io_link_firmware=N / IO01 v1.0.0 | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין |
| מומנט נומינלי | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | 0.5 Nm | 0.5 Nm | 0.5 Nm | 0.5 Nm | 0.5 Nm | 1 Nm | 1 Nm | 1 Nm | 1 Nm | 1 Nm | 10 Nm | 10 Nm | 10 Nm | 10 Nm | 10 Nm | 100 Nm | 100 Nm | 100 Nm | 100 Nm | 100 Nm | 2 Nm | 2 Nm | 2 Nm | 2 Nm | 2 Nm | 20 Nm | 20 Nm | 20 Nm | 20 Nm | 20 Nm | 200 Nm | 200 Nm | 200 Nm | 200 Nm | 200 Nm | 5 Nm | 5 Nm | 5 Nm | 5 Nm | 5 Nm | 50 Nm | 50 Nm | 50 Nm | 50 Nm | 50 Nm | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין |
| יציאה חשמלית בתצורה הנבחרת | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | frequency_analog | frequency_analog | frequency_analog | io_link | io_link | frequency_analog | frequency_analog | frequency_analog | io_link | io_link | frequency_analog | frequency_analog | frequency_analog | io_link | io_link | frequency_analog | frequency_analog | frequency_analog | io_link | io_link | frequency_analog | frequency_analog | frequency_analog | io_link | io_link | frequency_analog | frequency_analog | frequency_analog | io_link | io_link | frequency_analog | frequency_analog | frequency_analog | io_link | io_link | frequency_analog | frequency_analog | frequency_analog | io_link | io_link | frequency_analog | frequency_analog | frequency_analog | io_link | io_link | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין |
| מומנט נומינלי | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין |
| טווח מומנט | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין |
| קצב דגימת ADC | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | לא צוין | 40000 samples/s | 40000 samples/s | 40000 samples/s | 40000 samples/s | 40000 samples/s | 40000 samples/s | 40000 samples/s | 40000 samples/s | 40000 samples/s |
| סטטוס | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל |
| גיליון נתונים | PDF — K-T210 · 0.5 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 0.5 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 0.5 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 0.5 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 0.5 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) (נפתח בלשונית חדשה) | PDF — K-T210 · 1 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 1 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 1 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 1 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 1 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) (נפתח בלשונית חדשה) | PDF — K-T210 · 10 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 10 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 10 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 10 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 10 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) (נפתח בלשונית חדשה) | PDF — K-T210 · 100 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 100 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 100 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 100 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 100 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) (נפתח בלשונית חדשה) | PDF — K-T210 · 2 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 2 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 2 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 2 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 2 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) (נפתח בלשונית חדשה) | PDF — K-T210 · 20 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 20 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 20 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 20 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 20 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) (נפתח בלשונית חדשה) | PDF — K-T210 · 200 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 200 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 200 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 200 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 200 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) (נפתח בלשונית חדשה) | PDF — K-T210 · 5 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 5 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 5 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 5 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 5 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) (נפתח בלשונית חדשה) | PDF — K-T210 · 50 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 50 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=1 (512 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 50 N·m · electrical_output=FA (frequency + analog); rotational_speed_system=2 (1024 pulses) (נפתח בלשונית חדשה) | PDF — K-T210 · 50 N·m · electrical_output=L (IO-Link); rotational_speed_system=0 (none) (נפתח בלשונית חדשה) | PDF — K-T210 · 50 N·m · electrical_output=L (IO-Link); rotational_speed_system=3 (IO-Link + speed system) (נפתח בלשונית חדשה) |
אביזרים תואמים
כבלים
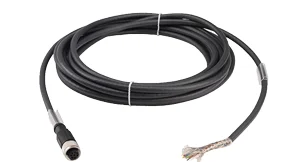
- 1-KAB434-5 eli-m-3be575bfa6d0cf834645a5e1 רק לתצורה configuration-56124e2112ddbab3f1874aef (K-T210 · 200 N·m configuration · accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=2 (1024 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0); יש להתאים את התצורה שנבחרה לפני הצגה.; רק למוצא FA של תדר ואנלוגי, לא לגרסת L עם IO-Link. KAB151A/KAB152 הם כבלים לקופסת VK20A ולא כבלים ישירים לחיישן. יש לאמת קוד מוצא ושקע כניסה לפני שימוש בחיווט T21WN קיים.
- 1-KAB435-10 eli-m-f9b367cb88fbb26aafd982fb רק לתצורה configuration-56124e2112ddbab3f1874aef (K-T210 · 200 N·m configuration · accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=2 (1024 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0); יש להתאים את התצורה שנבחרה לפני הצגה.; רק למוצא FA של תדר ואנלוגי, לא לגרסת L עם IO-Link. KAB151A/KAB152 הם כבלים לקופסת VK20A ולא כבלים ישירים לחיישן. יש לאמת קוד מוצא ושקע כניסה לפני שימוש בחיווט T21WN קיים.
- 3-3312.0268 eli-m-a4c2377bc261f57e0a4f4ec3 רק לתצורה configuration-56124e2112ddbab3f1874aef (K-T210 · 200 N·m configuration · accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=2 (1024 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0); יש להתאים את התצורה שנבחרה לפני הצגה.; רק למוצא FA של תדר ואנלוגי, לא לגרסת L עם IO-Link. KAB151A/KAB152 הם כבלים לקופסת VK20A ולא כבלים ישירים לחיישן. יש לאמת קוד מוצא ושקע כניסה לפני שימוש בחיווט T21WN קיים.
- 1-VK20A eli-m-07414d700a111231537289da רק לתצורה configuration-56124e2112ddbab3f1874aef (K-T210 · 200 N·m configuration · accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=2 (1024 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0); יש להתאים את התצורה שנבחרה לפני הצגה.; רק למוצא FA של תדר ואנלוגי, לא לגרסת L עם IO-Link. KAB151A/KAB152 הם כבלים לקופסת VK20A ולא כבלים ישירים לחיישן. יש לאמת קוד מוצא ושקע כניסה לפני שימוש בחיווט T21WN קיים.
- 1-KAB151A-1.5 eli-m-9b502810dbbb2733aac512fc רק לתצורה configuration-56124e2112ddbab3f1874aef (K-T210 · 200 N·m configuration · accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=2 (1024 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0); יש להתאים את התצורה שנבחרה לפני הצגה.; רק למוצא FA של תדר ואנלוגי, לא לגרסת L עם IO-Link. KAB151A/KAB152 הם כבלים לקופסת VK20A ולא כבלים ישירים לחיישן. יש לאמת קוד מוצא ושקע כניסה לפני שימוש בחיווט T21WN קיים.
- 1-KAB152-1.5 eli-m-f295114b154e720604fa66ea רק לתצורה configuration-56124e2112ddbab3f1874aef (K-T210 · 200 N·m configuration · accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=FA (frequency + analog);rotational_speed_system=2 (1024 pulses);custom_modification=N;io_link_firmware=N / IO01 v1.0.0); יש להתאים את התצורה שנבחרה לפני הצגה.; רק למוצא FA של תדר ואנלוגי, לא לגרסת L עם IO-Link. KAB151A/KAB152 הם כבלים לקופסת VK20A ולא כבלים ישירים לחיישן. יש לאמת קוד מוצא ושקע כניסה לפני שימוש בחיווט T21WN קיים.
התקנה
- 1-4413.00xx / K-MBC eli-m-05cb12a8db1512f72c6ee563 רק לתצורה configuration-8e760ae93410cae780380c3a (K-T210 · 200 N·m configuration · accuracy=S;maximum_speed=S;size_length=170 mm (50–200 N·m);electrical_output=L (IO-Link);rotational_speed_system=3 (IO-Link + speed system);custom_modification=N;io_link_firmware=N / IO01 v1.0.0); יש להתאים את התצורה שנבחרה לפני הצגה.; יש לבחור את שני קוטרי הקדח, מומנט נקוב, מהירות, אי־יישור מותר ומומנט אינרציה. D1 מותאם לצד המתמר ו־D2 לצד ציר ההנעה; זו הגדרת משפחה ולא קוד מצמד סופי להזמנה.
שאלות נפוצות
תשובות לשאלות הנפוצות ביותר על המוצרים והשירותים שלנו
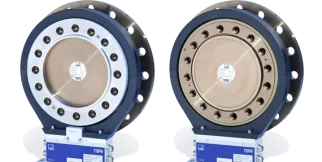
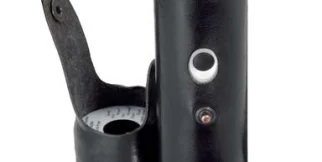
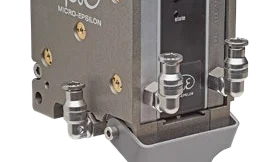
T210 הוא מתמר מומנט בעל קצוות גליליים לחיבור חיכוך. נתוני המדידה מועברים ללא מגע בין החלק המסתובב לחלק הנייח.
לא. זו הגדרת אות התדר שמייצג מומנט. יש להבדיל בינו לבין קצב מדידה או רוחב פס, ולא להציג 15 kHz כתדר דגימה על סמך אות היציאה.
לא. היצרן מציג גרסאות עם מדידת מהירות ובלעדיה, לרבות 512 או 1024 פולסים לסיבוב לפי התצורה.
לא. IO-Link מופיע כאפשרות נפרדת. יש לבחור את יציאות האות ואת אלקטרוניקת הקליטה לפי קוד ההזמנה.
לא בגרסת IO-Link המתועדת. הדגימה הפנימית היא 20 kHz, אך זמן המחזור המזערי של הממשק הוא 1.4 ms, ולמסלול יש גם מסננים משלו. מבחינים בין הדגימה הפנימית, קצב העברת הנתונים ורוחב הפס הנבחר.
קבלו הצעה או התייעצות
ספרו לנו מה אתם צריכים ומהנדס שלנו יחזור אליכם.
בקשת הצעת מחיר למוצר הזה