HM מערכות איזון
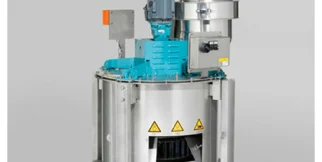
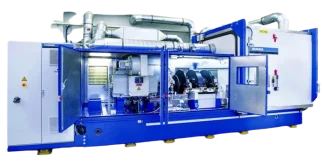
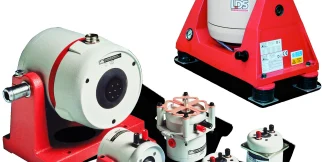
HM — מערכת של Schenck RoTec בתחום מערכות איזון.
לאתר של Schenck RoTec (נפתח בלשונית חדשה)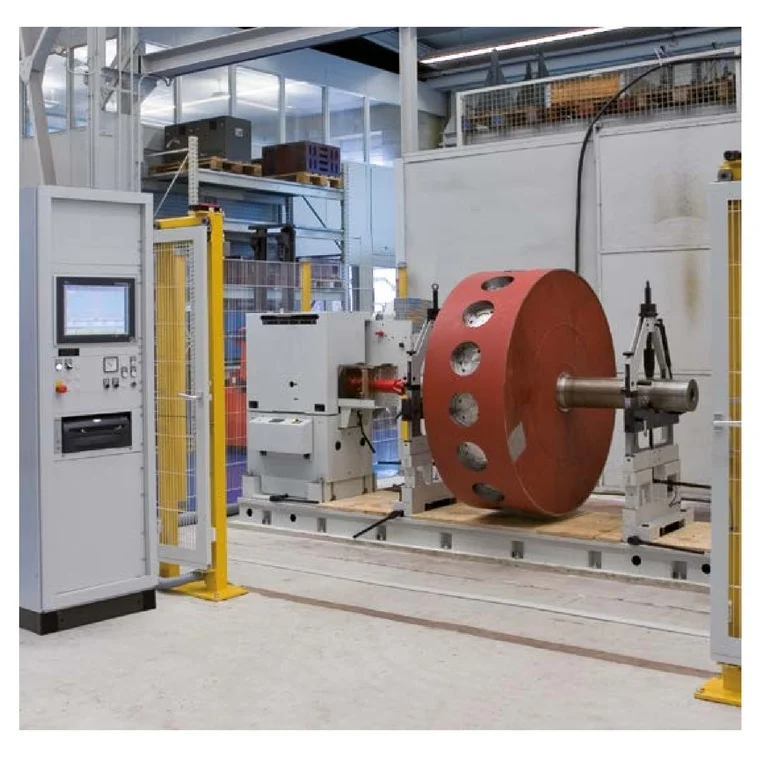
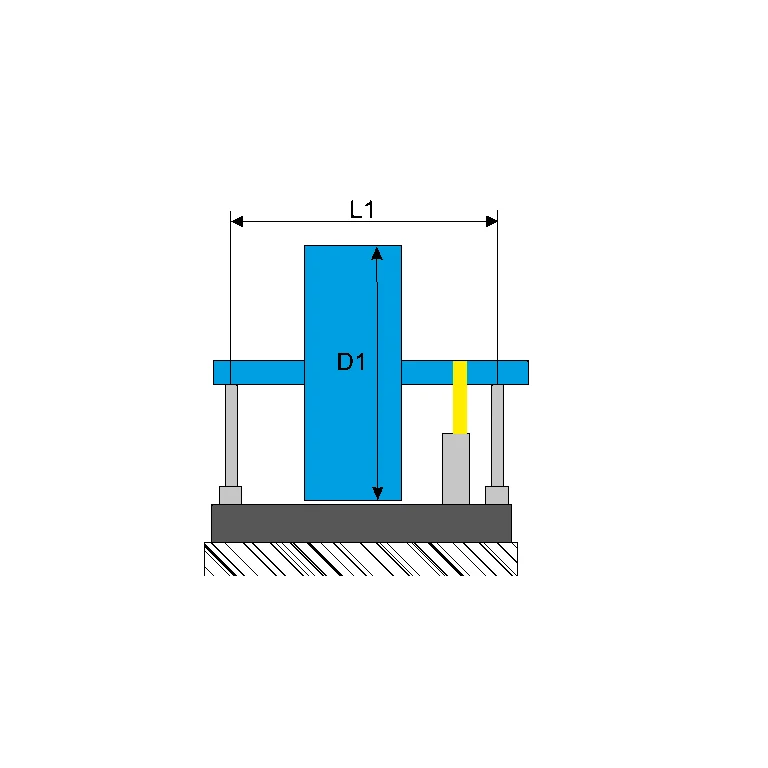
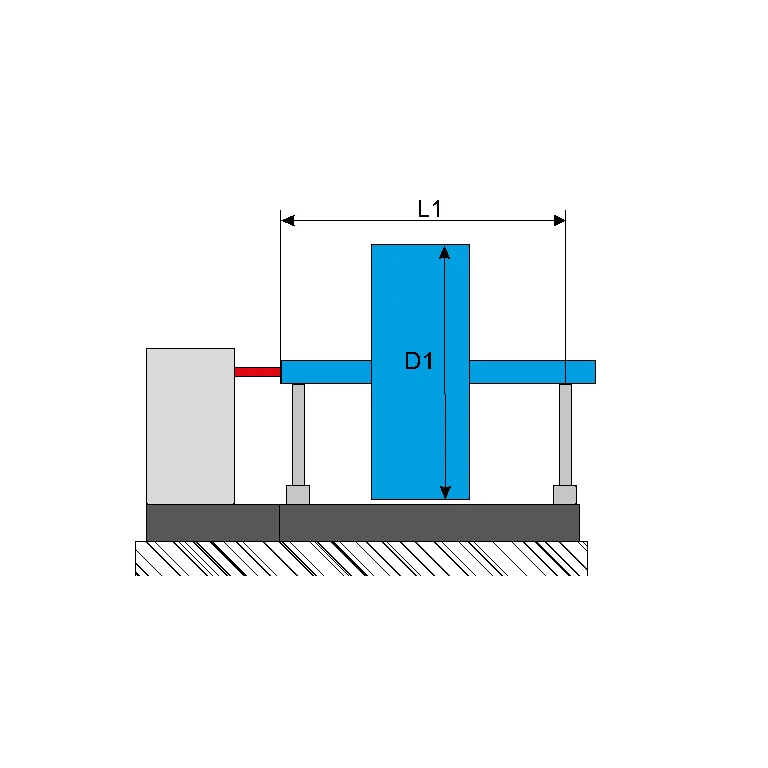
מפרט טכני משותף לסדרה
תכונות שיש לכל דגם בסדרה. מה שמשתנה בין הדגמים מופיע בטבלת הדגמים שלמטה.
טווח על פני הדגמים
הטווח שמכסים דגמי הסדרה יחד – לא הטווח של כל דגם.
| מסת רוטור מרבית | 10–250000 kg |
|---|---|
| אי־איזון שיורי מזערי | 0.1–240 g·mm |
| קוטר רוטור מרבי | 360–3600 mm |
הדגמים בסדרה
עמודה לכל דגם: מה שונה בין דגמי הסדרה.
| פרמטר | HM 1 eli-m-a212a7a772a37897989bf227 | HM 10 eli-m-0bf0838280c2bfa6c67da9af | HM 2 eli-m-f4b7056f6dbfa83b1e5cefd0 | HM 20 eli-m-3b1d2d37ce25aebd6df6409a | HM 3 eli-m-188e7a63ed5ce869bc816d00 | HM 30 eli-m-a5b08fdde57bb8fdc72f6fd3 | HM 4 eli-m-73f34c2e6aaeade5925e2661 | HM 40 eli-m-1bd57b16242058aafea789de | HM 5 eli-m-d35567d9934aa6ff4bebe0b6 | HM 50 eli-m-6472976743942015614025aa | HM 6 eli-m-2be817add8f7d1661af96026 | HM 60 eli-m-7fc7607b16c0d59f106212cc | HM 7 eli-m-8688f15f7295ee3870e2556e | HM 70 eli-m-5312cf35c4fb1c32f74f975a | HM 8 eli-m-670c11f272ecc1c98424a417 | HM 80 eli-m-41bbe4c46f468bddd70bc2f0 |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| סוג מערכת איזון | Universal horizontal | Universal horizontal | Universal horizontal | Universal horizontal | Universal horizontal | Universal horizontal | Universal horizontal | Universal horizontal | Universal horizontal | Universal horizontal | Universal horizontal | Universal horizontal | Universal horizontal | Universal horizontal | Universal horizontal | Universal horizontal |
| נתון טכני לפי גודל ובסיס במקור | 10 kg maximum rotor; 360 mm maximum rotor diameter; 0.1 gmm minimum achievable residual unbalance. | 18 kg maximum rotor; 360 mm maximum rotor diameter; 0.2 gmm minimum achievable residual unbalance. | 60 kg maximum rotor; 800 mm maximum rotor diameter; 1 gmm minimum achievable residual unbalance. | 120 kg maximum rotor; 800 mm maximum rotor diameter; 1.6 gmm minimum achievable residual unbalance. | 300 kg maximum rotor; 1260 mm maximum rotor diameter; 2 gmm minimum achievable residual unbalance. | 700 kg maximum rotor; 1260 mm maximum rotor diameter; 3 gmm minimum achievable residual unbalance. | 1500 kg maximum rotor; 1600 mm maximum rotor diameter; 5 gmm minimum achievable residual unbalance. | 3000 kg maximum rotor; 1600 mm maximum rotor diameter; 8 gmm minimum achievable residual unbalance. | 5500 kg maximum rotor; 1600 mm maximum rotor diameter; 16 gmm minimum achievable residual unbalance. | 8000 kg maximum rotor; 1600 mm maximum rotor diameter; 20 gmm minimum achievable residual unbalance. | 12500 kg maximum rotor; 2100 mm maximum rotor diameter; 30 gmm minimum achievable residual unbalance. | 20000 kg maximum rotor; 2100 mm maximum rotor diameter; 40 gmm minimum achievable residual unbalance. | 32000 kg maximum rotor; 2800 mm maximum rotor diameter; 64 gmm minimum achievable residual unbalance. | 50000 kg maximum rotor; 2800 mm maximum rotor diameter; 80 gmm minimum achievable residual unbalance. | 125000 kg maximum rotor; 3600 mm maximum rotor diameter; 160 gmm minimum achievable residual unbalance. | 250000 kg maximum rotor; 3600 mm maximum rotor diameter; 240 gmm minimum achievable residual unbalance. |
| פרטי ממשק ואות לפי המקור | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O |
| מסת רוטור מרבית | 10 kg | 18 kg | 60 kg | 120 kg | 300 kg | 700 kg | 1500 kg | 3000 kg | 5500 kg | 8000 kg | 12500 kg | 20000 kg | 32000 kg | 50000 kg | 125000 kg | 250000 kg |
| בסיס הגדרת חזרתיות | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. | Verify repeatability with the production rotor, fixture, correction process and operating-speed sequence. |
| ממשקים מובנים | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet |
| בסיס קצב הדגימה | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. | Balancing measurement speed and cycle are configured for the rotor and machine; no unsupported universal sample rate is inferred. |
| אי־איזון שיורי מזערי | 0.1 g·mm | 0.2 g·mm | 1 g·mm | 1.6 g·mm | 2 g·mm | 3 g·mm | 5 g·mm | 8 g·mm | 16 g·mm | 20 g·mm | 30 g·mm | 40 g·mm | 64 g·mm | 80 g·mm | 160 g·mm | 240 g·mm |
| בסיס הגדרת לינאריות | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. | Use the residual-unbalance and uncertainty specification of the quoted rotor / tooling configuration. |
| קוטר רוטור מרבי | 360 mm | 360 mm | 800 mm | 800 mm | 1260 mm | 1260 mm | 1600 mm | 1600 mm | 1600 mm | 1600 mm | 2100 mm | 2100 mm | 2800 mm | 2800 mm | 3600 mm | 3600 mm |
| סטטוס | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל | פעיל |
| גיליון נתונים | PDF — HM 1 (נפתח בלשונית חדשה) | PDF — HM 10 (נפתח בלשונית חדשה) | PDF — HM 2 (נפתח בלשונית חדשה) | PDF — HM 20 (נפתח בלשונית חדשה) | PDF — HM 3 (נפתח בלשונית חדשה) | PDF — HM 30 (נפתח בלשונית חדשה) | PDF — HM 4 (נפתח בלשונית חדשה) | PDF — HM 40 (נפתח בלשונית חדשה) | PDF — HM 5 (נפתח בלשונית חדשה) | PDF — HM 50 (נפתח בלשונית חדשה) | PDF — HM 6 (נפתח בלשונית חדשה) | PDF — HM 60 (נפתח בלשונית חדשה) | PDF — HM 7 (נפתח בלשונית חדשה) | PDF — HM 70 (נפתח בלשונית חדשה) | PDF — HM 8 (נפתח בלשונית חדשה) | PDF — HM 80 (נפתח בלשונית חדשה) |
שאלות נפוצות
תשובות לשאלות הנפוצות ביותר על המוצרים והשירותים שלנו
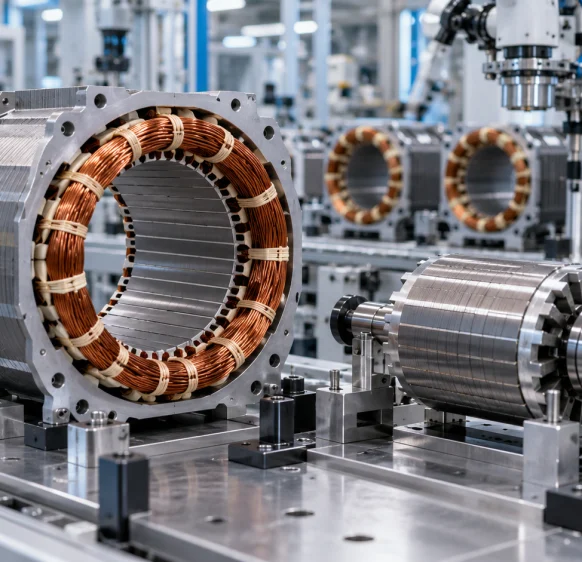
הסדרה האופקית מיועדת לרוטורים גליליים בעלי צווארי ציר ולרוטורים דיסקיים המותקנים על ציר איזון מתאים.
תכנון מודולרי, אביזרים ומבנה תמיכות קשיחות מאפשרים שינוי הכנה, והסדרה מתוארת כבעלת כיול קבוע. עדיין יש להתאים דפינה ומיגון לכל רוטור.
לא. בטבלת HM 4, HM 40, HM 5 ו־HM 50 מופיעות קיבולות של 1500, 3000, 5500 ו־8000 kg, בהתאמה.
הנעת BU ברצועה מתאימה למגוון רוטורים. הנעת U במפרק אוניברסלי נבחרת כשנדרש הספק הנעה גבוה. צורת הרוטור ודרישת ההספק קובעות.
לפי מהירות האיזון, הסיכון למגע ואנרגיית חלקים שעלולים להינתק. מיגון מפני מגע ומיגון מפני רסיסים הם דרישות שונות.
קבלו הצעה או התייעצות
ספרו לנו מה אתם צריכים ומהנדס שלנו יחזור אליכם.
בקשת הצעת מחיר למוצר הזה