HM Balancing systems
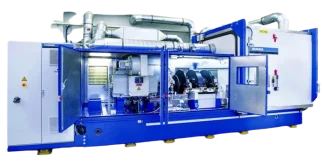
HM: system by Schenck RoTec for balancing systems.
Visit the Schenck RoTec site (opens in a new tab)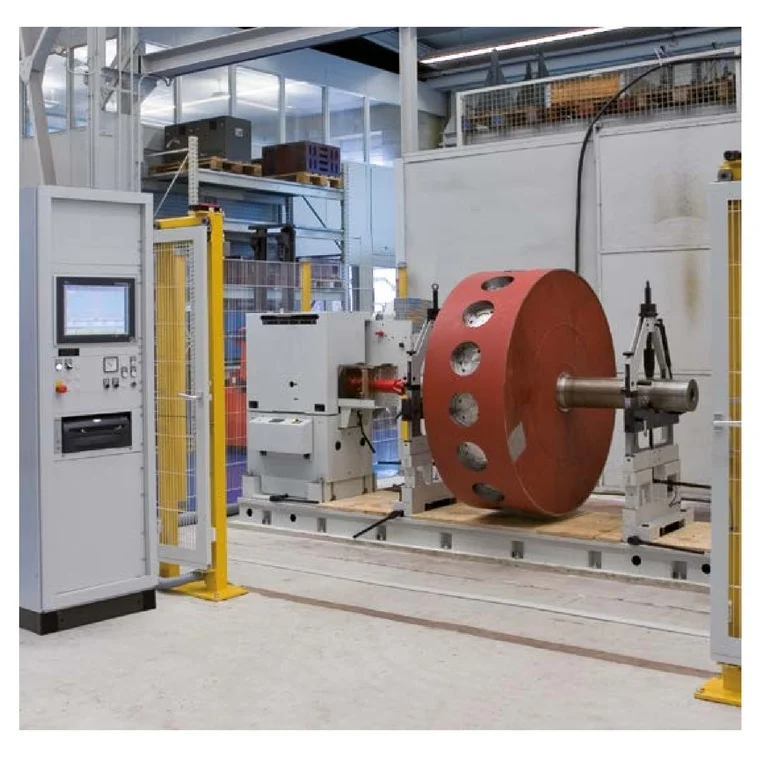
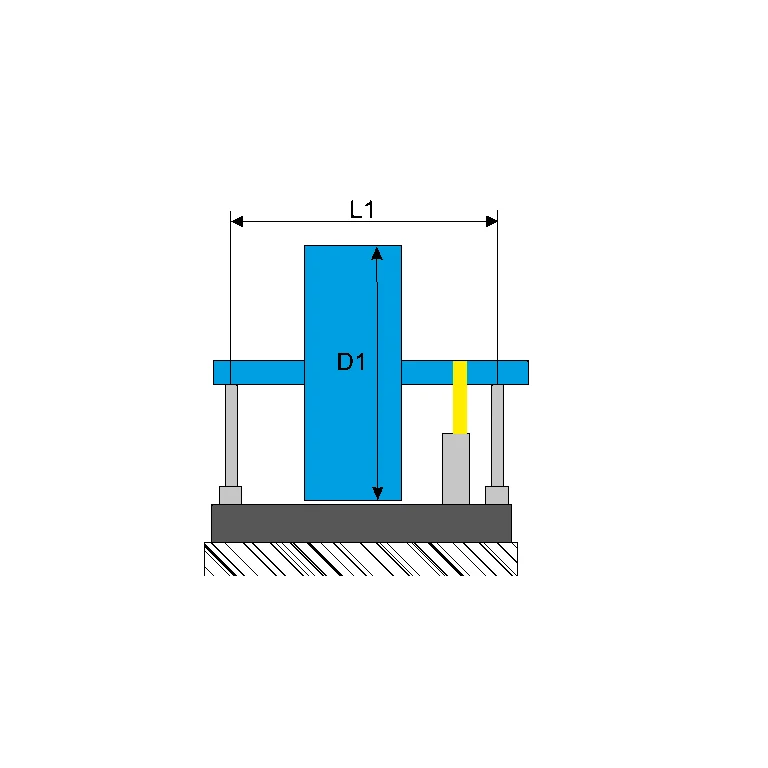
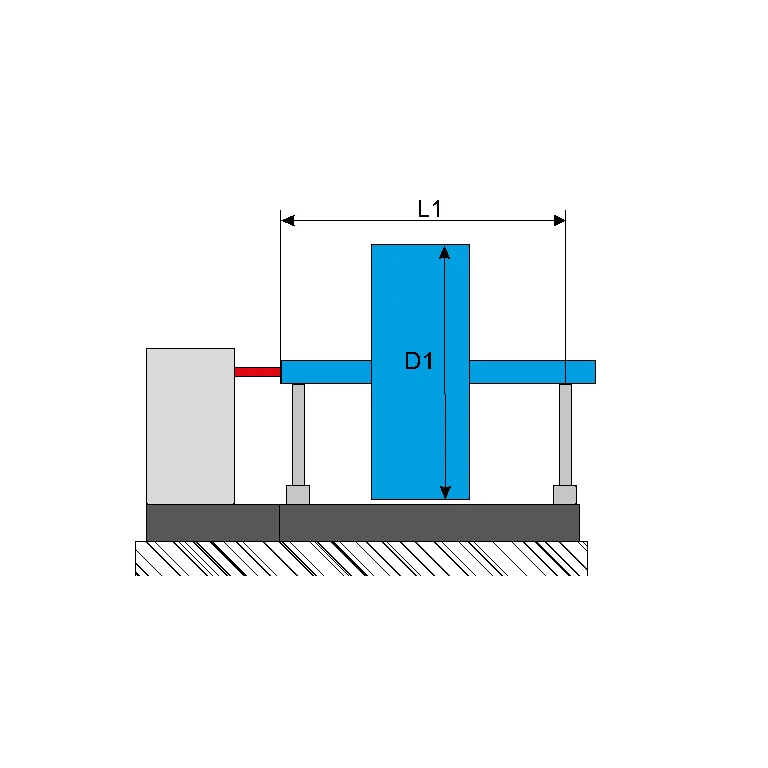
Shared technical specifications for the series
Properties every model in the series has. What differs is in the models table below.
Range across models
The span covered by the models of the series together — not the range of each model.
| Maximum rotor mass | 10–250000 kg |
|---|---|
| Minimum residual unbalance | 0.1–240 g·mm |
| Maximum rotor diameter | 360–3600 mm |
Models in the series
One column per model: what differs between the models of the series.
| Parameter | HM 1 eli-m-a212a7a772a37897989bf227 | HM 10 eli-m-0bf0838280c2bfa6c67da9af | HM 2 eli-m-f4b7056f6dbfa83b1e5cefd0 | HM 20 eli-m-3b1d2d37ce25aebd6df6409a | HM 3 eli-m-188e7a63ed5ce869bc816d00 | HM 30 eli-m-a5b08fdde57bb8fdc72f6fd3 | HM 4 eli-m-73f34c2e6aaeade5925e2661 | HM 40 eli-m-1bd57b16242058aafea789de | HM 5 eli-m-d35567d9934aa6ff4bebe0b6 | HM 50 eli-m-6472976743942015614025aa | HM 6 eli-m-2be817add8f7d1661af96026 | HM 60 eli-m-7fc7607b16c0d59f106212cc | HM 7 eli-m-8688f15f7295ee3870e2556e | HM 70 eli-m-5312cf35c4fb1c32f74f975a | HM 8 eli-m-670c11f272ecc1c98424a417 | HM 80 eli-m-41bbe4c46f468bddd70bc2f0 |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| quantity_specification | 10 kg maximum rotor; 360 mm maximum rotor diameter; 0.1 gmm minimum achievable residual unbalance. | 18 kg maximum rotor; 360 mm maximum rotor diameter; 0.2 gmm minimum achievable residual unbalance. | 60 kg maximum rotor; 800 mm maximum rotor diameter; 1 gmm minimum achievable residual unbalance. | 120 kg maximum rotor; 800 mm maximum rotor diameter; 1.6 gmm minimum achievable residual unbalance. | 300 kg maximum rotor; 1260 mm maximum rotor diameter; 2 gmm minimum achievable residual unbalance. | 700 kg maximum rotor; 1260 mm maximum rotor diameter; 3 gmm minimum achievable residual unbalance. | 1500 kg maximum rotor; 1600 mm maximum rotor diameter; 5 gmm minimum achievable residual unbalance. | 3000 kg maximum rotor; 1600 mm maximum rotor diameter; 8 gmm minimum achievable residual unbalance. | 5500 kg maximum rotor; 1600 mm maximum rotor diameter; 16 gmm minimum achievable residual unbalance. | 8000 kg maximum rotor; 1600 mm maximum rotor diameter; 20 gmm minimum achievable residual unbalance. | 12500 kg maximum rotor; 2100 mm maximum rotor diameter; 30 gmm minimum achievable residual unbalance. | 20000 kg maximum rotor; 2100 mm maximum rotor diameter; 40 gmm minimum achievable residual unbalance. | 32000 kg maximum rotor; 2800 mm maximum rotor diameter; 64 gmm minimum achievable residual unbalance. | 50000 kg maximum rotor; 2800 mm maximum rotor diameter; 80 gmm minimum achievable residual unbalance. | 125000 kg maximum rotor; 3600 mm maximum rotor diameter; 160 gmm minimum achievable residual unbalance. | 250000 kg maximum rotor; 3600 mm maximum rotor diameter; 240 gmm minimum achievable residual unbalance. |
| interface_specification | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O | Digital I/O |
| Maximum rotor mass | 10 kg | 18 kg | 60 kg | 120 kg | 300 kg | 700 kg | 1500 kg | 3000 kg | 5500 kg | 8000 kg | 12500 kg | 20000 kg | 32000 kg | 50000 kg | 125000 kg | 250000 kg |
| Interfaces | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet | ethernet |
| Minimum residual unbalance | 0.1 g·mm | 0.2 g·mm | 1 g·mm | 1.6 g·mm | 2 g·mm | 3 g·mm | 5 g·mm | 8 g·mm | 16 g·mm | 20 g·mm | 30 g·mm | 40 g·mm | 64 g·mm | 80 g·mm | 160 g·mm | 240 g·mm |
| Maximum rotor diameter | 360 mm | 360 mm | 800 mm | 800 mm | 1260 mm | 1260 mm | 1600 mm | 1600 mm | 1600 mm | 1600 mm | 2100 mm | 2100 mm | 2800 mm | 2800 mm | 3600 mm | 3600 mm |
| Status | Active | Active | Active | Active | Active | Active | Active | Active | Active | Active | Active | Active | Active | Active | Active | Active |
| Datasheet | PDF — HM 1 (opens in a new tab) | PDF — HM 10 (opens in a new tab) | PDF — HM 2 (opens in a new tab) | PDF — HM 20 (opens in a new tab) | PDF — HM 3 (opens in a new tab) | PDF — HM 30 (opens in a new tab) | PDF — HM 4 (opens in a new tab) | PDF — HM 40 (opens in a new tab) | PDF — HM 5 (opens in a new tab) | PDF — HM 50 (opens in a new tab) | PDF — HM 6 (opens in a new tab) | PDF — HM 60 (opens in a new tab) | PDF — HM 7 (opens in a new tab) | PDF — HM 70 (opens in a new tab) | PDF — HM 8 (opens in a new tab) | PDF — HM 80 (opens in a new tab) |
The industries we serve
-
-
Aerospace
- Aircraft door-lock position detection
- Airlines & Aerospace Our balancing machines and moment weighing scales for aerospace drives ensure maximum precision, ease of use, and modular flexibility delivering reliability and performance without compromise contributing to your economic success.
- Automatic balancing machines Automatic balancing machines from Schenck are advanced solutions for precise balancing of rotating components in automated production processes. We offer systems and stations for balancing crankshafts, wheels and tires, turbochargers, electric armatures, drives, axle drive units, torque converters, drive shafts, disc-shaped rotors, as well as fans. Our systems increase productivity, ensure consistent quality, and are tailored to the needs of the automotive, energy, and industrial sectors.
-
Medical industry
-
Environment
-
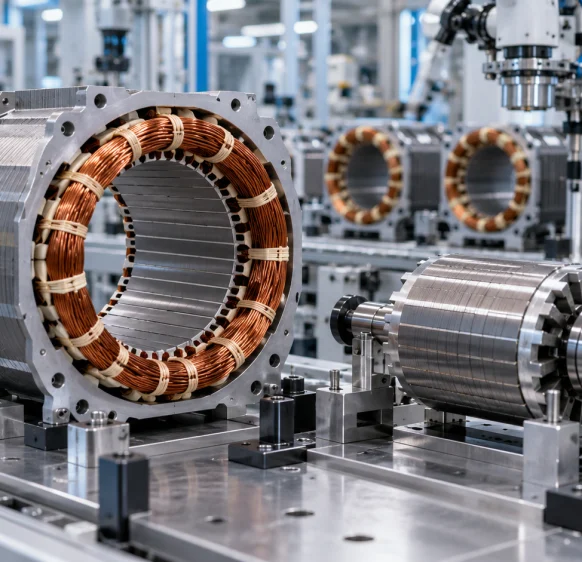
Electric motor manufacturing
-
Food industry
-
Automotive industry
- Airlines & Aerospace Our balancing machines and moment weighing scales for aerospace drives ensure maximum precision, ease of use, and modular flexibility delivering reliability and performance without compromise contributing to your economic success.
- Automatic balancing machines Automatic balancing machines from Schenck are advanced solutions for precise balancing of rotating components in automated production processes. We offer systems and stations for balancing crankshafts, wheels and tires, turbochargers, electric armatures, drives, axle drive units, torque converters, drive shafts, disc-shaped rotors, as well as fans. Our systems increase productivity, ensure consistent quality, and are tailored to the needs of the automotive, energy, and industrial sectors.
- Axle Drives With our balancing machines for front and rear axle transmissions, the measured unbalance is corrected by drilling into the drive flanges of the transmissions (welding optional). We support you with our interdisciplinary expertise in the production of front and rear axle transmissions from the initial idea to the design stage through to series production.
-
Industrial automation
-
Plastics
-
Optics
-
3D printing
-
Battery manufacturing
Frequently asked questions
Answers to the most common questions about our products and services
The horizontal family supports cylindrical rotors with integral journals and disc-shaped rotors mounted on suitable balancing arbors.
Its modular design, accessories and hard-bearing construction support changeovers, with permanent calibration. Tooling and protection must still suit each rotor.
No. The HM 4, HM 40, HM 5 and HM 50 table specifies 1500, 3000, 5500 and 8000 kg capacities respectively.
BU belt drive serves varied rotor shapes. U universal-joint drive serves high drive-power requirements. Rotor geometry and required drive power determine the selection.
Consider balancing speed, contact hazards and possible fragment energy. Protection against contact and containment of projected fragments are different requirements.
Get a quote or advice
Tell us what you need and an engineer will come back to you.
Request a quote for this product